Meinong Robot: AI Achieves Better Agriculture

Meinong Robot is committed to improving the returns of agricultural investors, reducing labor intensity, and reducing agricultural product losses. Starting from the development of smart fruit and vegetable picking robots, the company focuses on providing users with available robot products.

Flagship Product

Vine-fruit harvesting robot

About MEINONG's vine-fruit harvesting robot: addressing orchard labor shortages driven by workforce aging, MEINONG ROBOT delivers a fully automated vine-fruit picking solution. AI vision enables millimeter-level positioning, 24/7 continuous operation, and integration with modern farm management platforms—for commercial vineyards, kiwifruit blocks and greenhouses worldwide.

CoreAI Vision
Precisionmm-level
Use CaseVine Fruit

Product Overview

The Vine-fruit harvesting robot(藤本水果采摘机器人)targets vine (liana) crops such as grapes, kiwifruit and passion fruit in trellis, pergola and greenhouse layouts. It combines deep learning, machine vision and multi-sensor fusion to detect fruit, assess maturity and harvest gently under variable lighting and foliage occlusion—easing peak-season labor pressure while improving batch consistency and traceability.
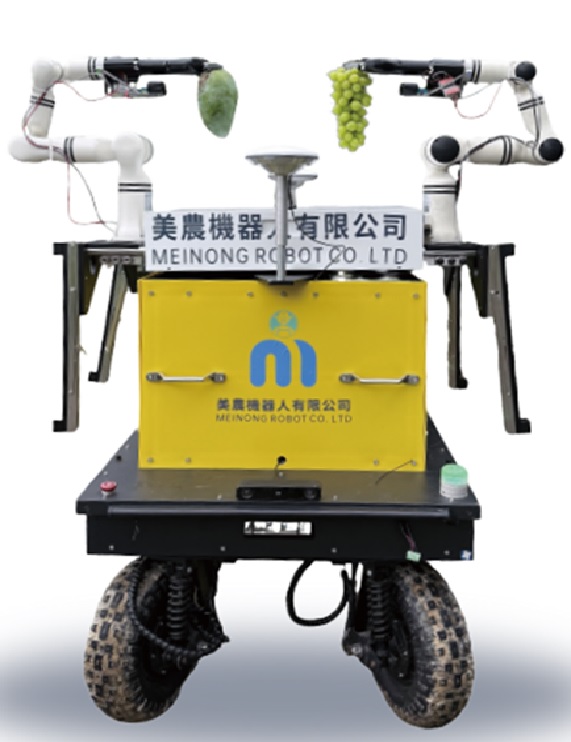
Vine-fruit harvesting robot

Core Technology

1. Fruit perception & policy

Multi-view imaging with temporal reasoning improves stability for clusters, overlaps and partial occlusion. Models and thresholds can be tuned per cultivar and grade standard, with closed-loop data iteration.

2. Soft harvesting execution

A multi-DOF arm with interchangeable end tools supports stem-cutting or twist-pull strategies with controlled contact forces and paths to limit skin damage and drop loss.

3. Row operations & orchestration

Fused localization and perception enable row travel, station keeping and obstacle avoidance; batch metrics can integrate with farm management systems for scheduling and quality traceability.

Highlights

1. More uniform commercial batches

Reduces maturity variability compared with purely manual crews.

2. Continuous harvesting capability

Designed for intensive harvest windows and repetitive tasks that strain human pickers.

3. Extensible workflows

Paths and cadence can evolve with typical vine crops, trellis structures and orchard practices.

Deployment note

Specific configurations, end-effectors and throughput targets depend on site assessment; contiguous blocks tend to yield better unit economics and data value.

MEINONG Harvesting Robot vs Manual Harvesting ROI Comparison

FactorManual HarvestingMEINONG Harvesting Robot (X-Picker)ROI & Business Impact
Daily Output & Speed400–600 kg/day per worker; afternoon fatigue causes notable slowdown6,000–7,500 kg/day per unit; ~10 seconds per cluster cycle6–10x productivity boost, locks in optimal Brix window
Nighttime Continuous HarvestingLow visibility, safety hazards, virtually impossible to organize at scaleIntegrated active lighting & stereo vision for full 24/7 continuous operationCool night picking reduces fruit respiration, extending shelf-life by 3–5 days
Fruit Damage & Drop LossRough handling during rush shifts leads to 8%–15% damage/lossVisual servoing + compliant stem-cutting gripper keeps damage below 5%Direct loss reduction yielding higher premium pack-out rates
Labor Shortage & CostAging rural workforce, severe peak labor shortages with soaring wage ratesRequires only 1 field safety operator per machine, saving >50% labor dependencyEliminates peak-season work stoppage risks and lowers injury claims

Technical & Operational Specifications

DimensionVine-fruit harvesting robot — specification
Core algorithmDeep learning with multi-sensor fusion for millimeter-level detection and positioning.
Picking strategyCompliant multi-DOF arm with crop-specific end-effectors.
Operating efficiencySupports high-volume, 6,000–7,500 kg/day, ~10s per cluster.
Damage controlCompliant cutting and soft handling keeps fruit damage strictly under 5%.
Digital managementProduction and QC traceability with farm management platform integration.

Frequently Asked Questions

QWhich crops and growing systems does the MEINONG vine-fruit picking robot support?
A
It is built for vine (liana) crops such as grapes, kiwifruit and passion fruit, and fits trellis, pergola and greenhouse cultivation layouts.
QWhat is the typical Return on Investment (ROI) period for the harvesting robot?
A
In contiguous commercial orchards across regions like Xinjiang or Queensland (Australia), one robot replaces the workload of 6–10 manual pickers while cutting damage rates below 5%. The equipment investment and operational cost are typically recouped within 1 to 2 harvest seasons.
QHow does the robot handle foliage occlusion and overlapping fruit clusters?
A
The system combines deep learning, machine vision and multi-sensor fusion. Multi-view imaging with temporal reasoning enables millimeter-level recognition and maturity assessment under variable light, clusters, overlaps and canopy occlusion.
QWill the robot mechanically damage fruit? How does MEINONG prevent loss?
A
MEINONG uses a multi-DOF arm with compliant end tools. Custom stem-cutting or twist-pull strategies control contact force and motion paths to minimize skin damage and drop loss.